Before GILMO can monitor the ocean, it has to learn to swim.
GILMO1 is the robot we build to learn what needs to be improved. It allows us to iterate fast and learn the difficulties that waterproofing and winged propulsion pose quickly.
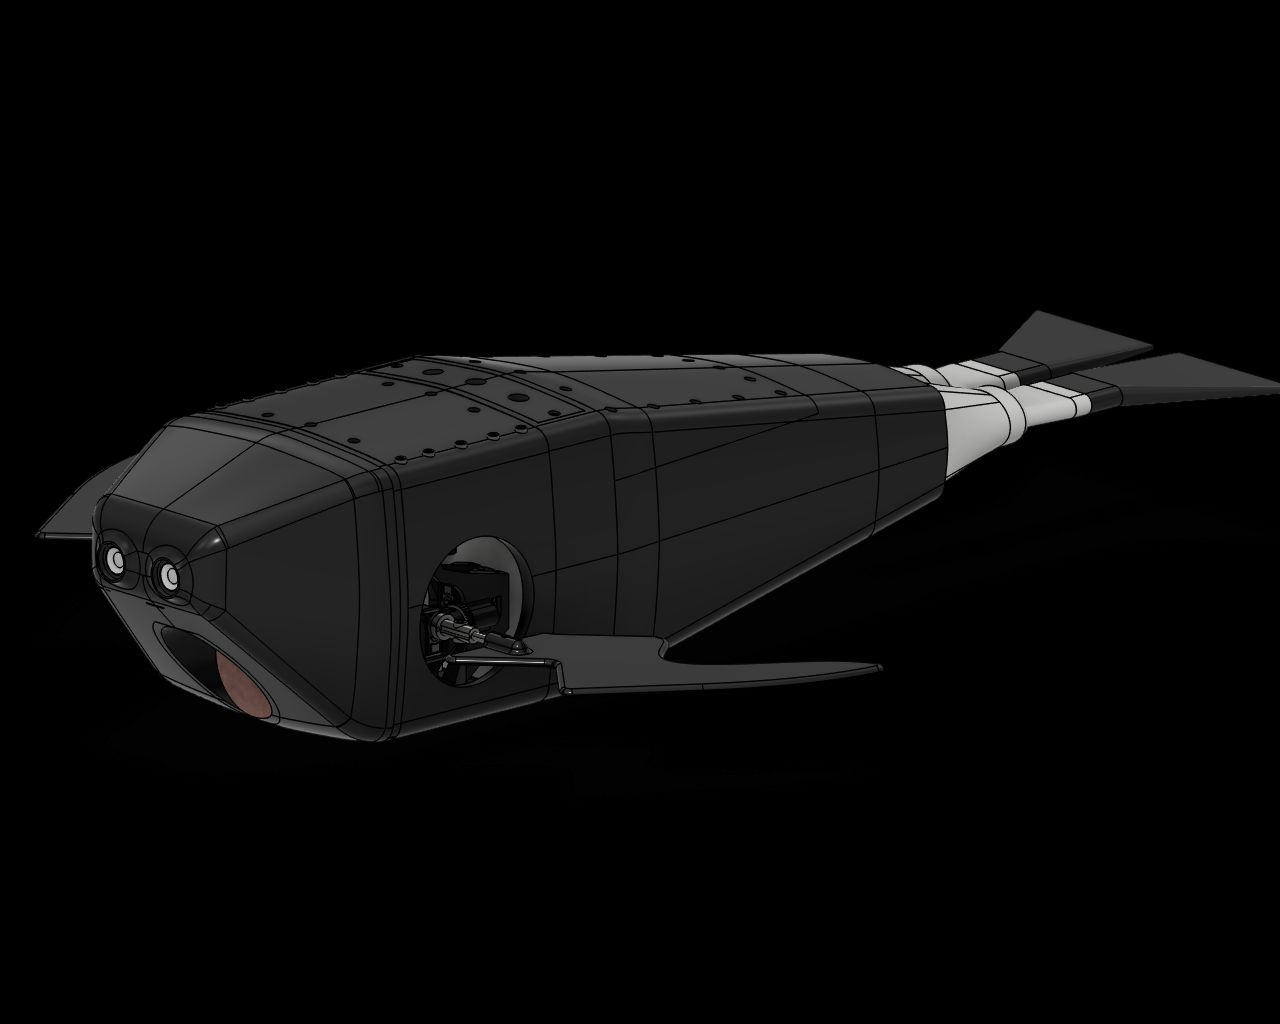
Make it exist first, make it perfect later.
Test manufacturing techniques
Every part is a trial of how we make it. What performs well carries over to GILMO2, what doesn't gets improved.
Controls testbed
Wing and fin stroke efficiency can be tested right away. With this we can not only iterate fast on controls, but also on wing design and optimal proportions.
Simulation validation
Each run is measured against our models, so the simulation becomes a more trustworthy tool because we know the sim-to-real gap.